Accessibility
Getting around when the street isn't built for you.
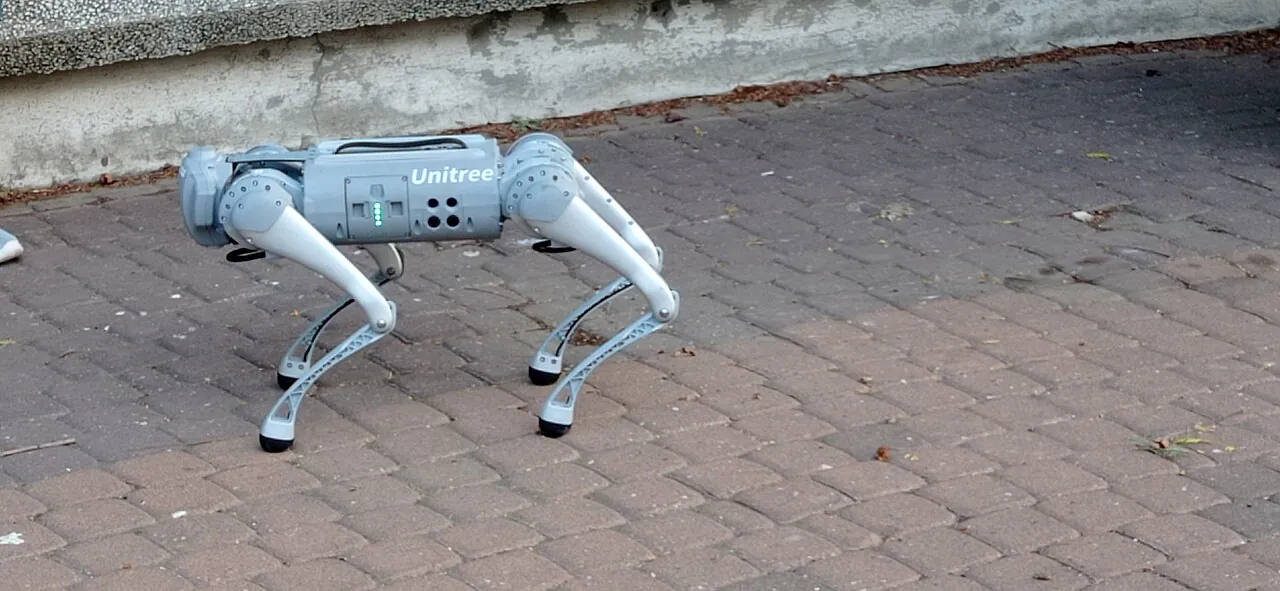

Pawthfinder
Talking crosswalks and curb ramps cost thousands of dollars each, so most streets don't have them. Our team's idea was to make the safety check travel with the person: plan a robotaxi ride and the walk to it as one trip, door to seat, with a robot guide dog for the walk.
I built the PyBullet simulation the guide dog runs in. The worlds are generated from OpenStreetMap data with flood and hazard layers, the robot reads the ground through depth-camera height maps, and it replans with A* every step. The team could watch it guide on real Miami street layouts within a weekend.
Sign-language avatar
As a research assistant, I'm part of ongoing work using AR glasses to drive an avatar that can communicate in and interpret sign language.